 Flowstone
Simulation · dual-arm
SFT Data in Simulation
Simulated dual-arm demonstrations written as multimodal agent conversations, for supervised fine-tuning of VLM agents. Each turn gives the robot its state and three camera images. It then writes a short first-person chain of thought and calls one tool, move. A last turn checks the task's goal in the final views and stops without a tool call.
Data spec
| Episodes | 3,500, one conversation each |
|---|---|
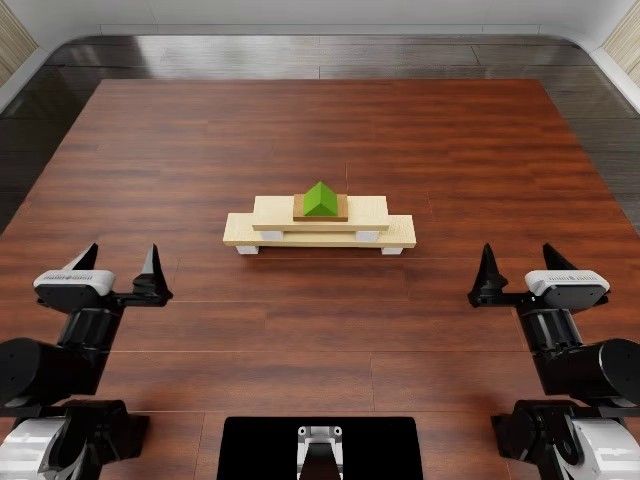
| Tasks | 35, with 100 episodes each |
| Steps | 89,056 assistant turns with a move call |
| Images | 277,668 embedded JPEGs at 640 × 480 |
| Cameras | Head and one wrist camera per arm, three images per step |
| Robot | A simulated dual-arm robot |
| Chain of thought | Median 92 words per assistant turn, 90th percentile 131, maximum 153 |
| Format | OpenAI chat and tool call messages, stored in Arrow |
| Size | 13.4 GB in 27 Arrow shards, about 4 MB per row |
One step
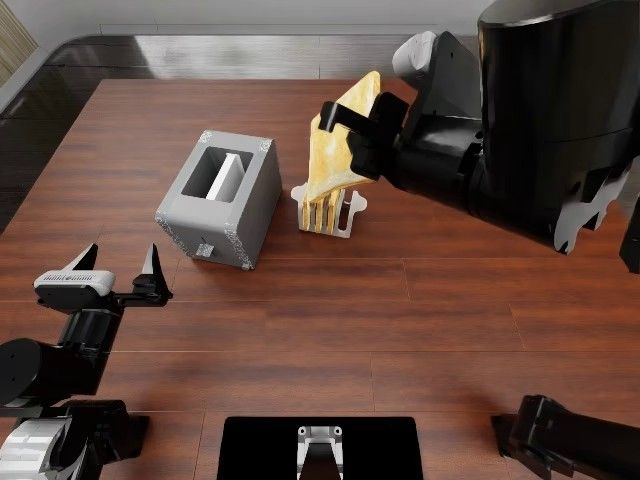
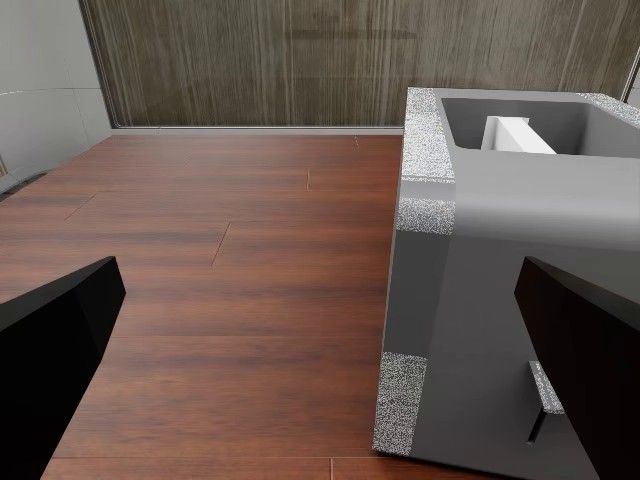
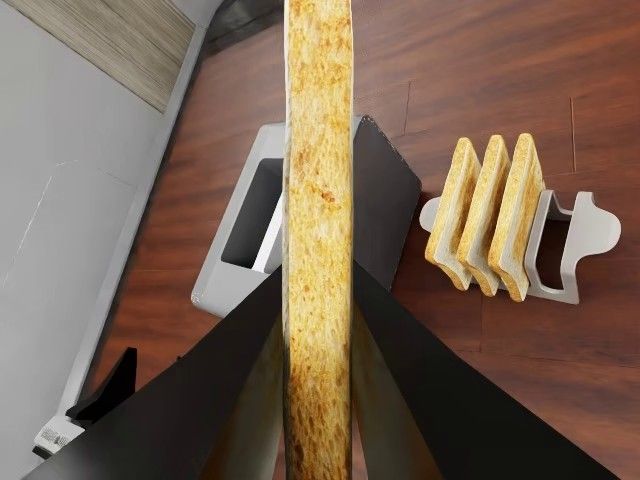
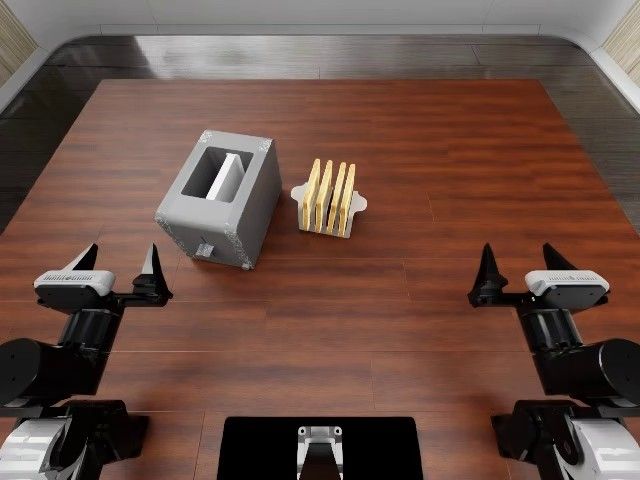
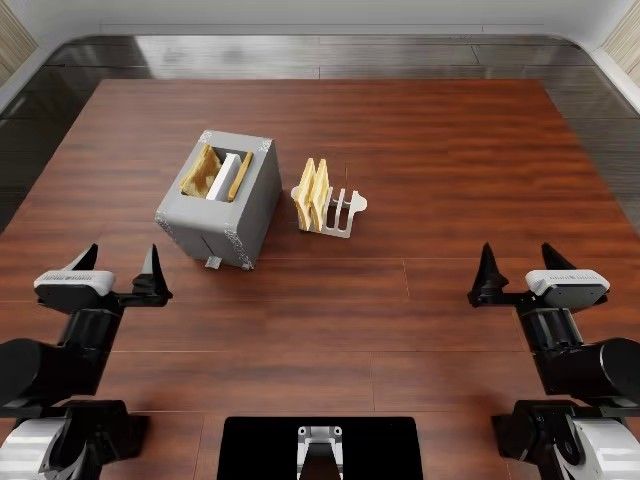
From an episode with the task: “Pick up two slices of bread, place them into the toaster, and press the lever down.” State values are shortened here.
- user
-
{"terminated": false, "success": false, "arms": {"left": {"fingertip_pose": {"position_mm": [-299.5750, -194.7300, 921.3599], "quaternion_wxyz": [0.7069, 0.0000, 0.0000, 0.7072]}, ...}, "right": {...}}}Camera: head; horizontal FOV 96 deg, vertical FOV 79.6 deg Camera: left_wrist; horizontal FOV 77.7 deg, vertical FOV 62.3 deg Camera: right_wrist; horizontal FOV 77.7 deg, vertical FOV 62.3 deg - assistant
-
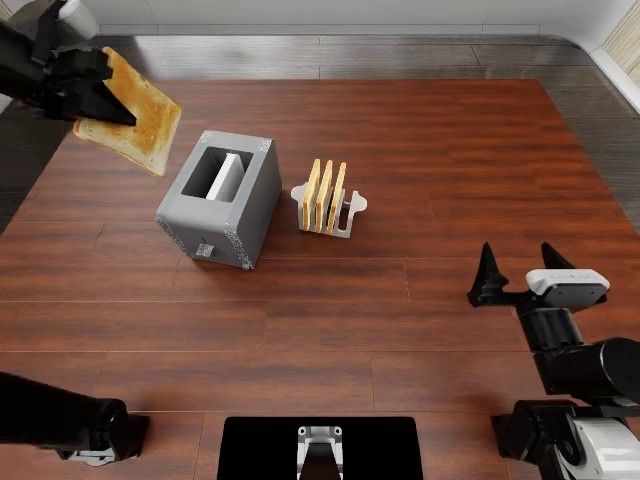
The lifted bread is clear of the holder beside the remaining slices. I'll bring my left hand toward it while my right hand positions it for transfer. I'll move my left gripper slightly forward, sideways, and upward, keeping its jaws open to approach the bread, turning 63 deg, rolling and yawing, with the fingers ending 15 deg below horizontal. I'll move my right gripper forward, sideways, and downward to present the bread, turning 43 deg, rolling and yawing, bringing its fingers from 27 to 10 deg below horizontal while maintaining its grip. My left move is (5, -136, 84) mm with rotation (-33, 32, -43) deg in my left gripper frame, staying open; my right move is (51, -39, -41) mm with rotation (33, 10, 26) deg in my right gripper frame, staying closed.
move {"left": {"delta_xyz": [5, -136, 84], "delta_rotation": [-33, 32, -43], "gripper_closed": false}, "right": {"delta_xyz": [51, -39, -41], "delta_rotation": [33, 10, 26], "gripper_closed": true}} - tool
{"state": {"terminated": false, "success": false, "arms": {"left": {"fingertip_pose": {"position_mm": [-163.6780, -189.2550, 1005.0650], "quaternion_wxyz": [0.8543, -0.3841, -0.0079, 0.3498]}, ...}, "right": {...}}}}
Across an episode
The head camera at three points in the same episode, which runs for 25 steps.
More tasks
Conversation
system: describes the robot, units, frames, and themovetool.user:Task: <instruction>.- Each step has three messages:
user: the state JSON (fingertip poses in mm, joint angles in degrees, gripper commands), then a label and image for each camera. The label gives the camera's horizontal and vertical field of view.assistant: the chain of thought and onemovecall, with arguments{"left": {"delta_xyz": [x, y, z], "delta_rotation": [rx, ry, rz], "gripper_closed": b}, "right": {...}}. Translations are in mm and rotations are rotation vectors in degrees, in the arm's current fingertip frame.tool:{"state": ...}, the measured state after the move.
user, thenassistant: the final state and views, then a completion reply with no tool call, which ends the episode.
Row schema
| Column | Type | Meaning |
|---|---|---|
episode | string | Episode ID, sim_<index> |
episode_index | int32 | 0 to 3499, grouped by task |
task | string | Task key |
robot | string | Robot name |
instruction | string | Task instruction |
messages | list of messages | The conversation |
images | list of Image | Every image in the conversation, in order of appearance |
tools | string | The OpenAI tools list as JSON: the move function and its JSON schema |
num_steps, num_images | int32 | Steps (tool calls) and images in the row |
A message has role, content, tool_calls, and tool_call_id, with one Arrow schema for every message. Fields a message does not use are null. content is always a list of parts {type, text, image_url: {url}}, and the k-th image part is images[k].
Conventions
- The fingertip frame has its origin midway between the fingertips, +X toward the fingertips, +Y across the jaws, and +Z = X × Y.
- A move is applied once, as T_goal = T_tip · T_delta. The controller drives the arms until they arrive or stop moving, then sets the gripper.
- Moves carry no step count or duration. How long a move runs is up to the controller.