 Flowstone
Real robots · dual-arm
SFT Data on Real Robots
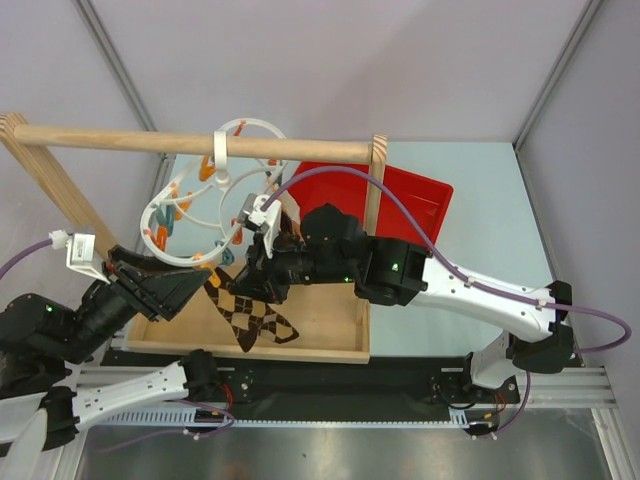
A real dual-arm robot doing household and tabletop tasks, written as multimodal agent conversations for supervised fine-tuning of VLM agents. Each turn gives the robot its state and three camera images. It then writes a short first-person chain of thought and calls one tool, move. A last turn looks at the final views, says whether the task's goal is met, and stops without a tool call.
Some episodes contain an attempt that does not work, such as a grasp that misses. The chain of thought says so once the views show it, and the following steps try again.
Data spec
| Episodes | 500, one conversation each |
|---|---|
| Tasks | 175 household and tabletop tasks, 2 to 3 episodes each |
| Steps | 75,375 assistant turns with a move call |
| Images | 227,625 embedded JPEGs at 640 × 480, 848 × 480, and 848 × 477 |
| Cameras | A fixed top view and one wrist view per arm, three images per step |
| Robot | A real dual-arm robot |
| Chain of thought | Median 133 words per assistant turn, 90th percentile 142, maximum 161 |
| Format | OpenAI chat and tool call messages, stored in Arrow |
| Size | 14.3 GB in 30 Arrow shards, about 30 MB per row |
One step
From an episode with the task: “decorate the small christmas tree.” State values are shortened here.
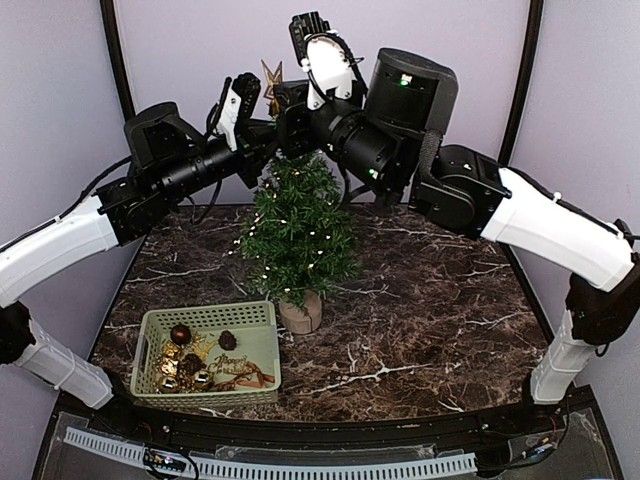
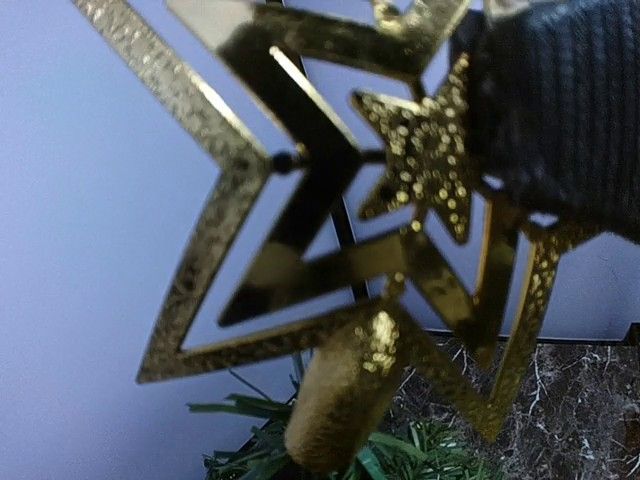
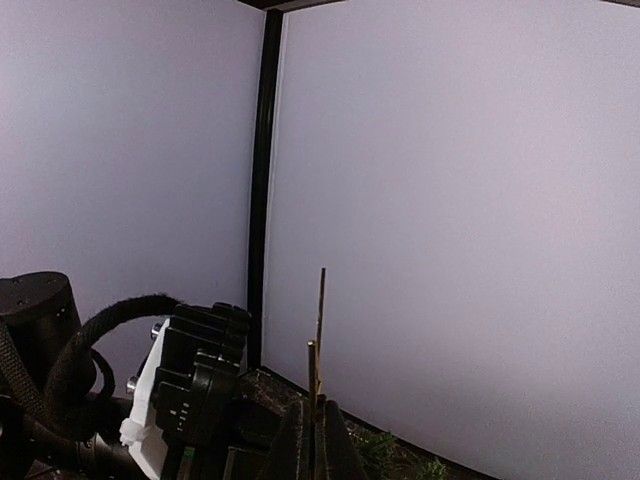
- user
-
{"terminated": false, "success": false, "arms": {"left": {"fingertip_pose": {"position_mm": [319.9422, -341.2891, 438.6333], "quaternion_wxyz": [0.8854, 0.0805, -0.1651, -0.4268]}, ...}, "right": {...}}}Camera: head; horizontal FOV 96.7 deg, vertical FOV 80.3 deg Camera: left_wrist; horizontal FOV 96.3 deg, vertical FOV 79.9 deg Camera: right_wrist; horizontal FOV 96.4 deg, vertical FOV 80.1 deg - assistant
-
My left fingers now brace the gold star alongside my right gripper. I’ll release my left grip and guide the topper onto the treetop with my right hand. The placement point is at (1, -11, -44) mm in my right gripper frame; I’ll aim for that point + (5, -8, 20) mm to approach the mounting position with clearance. I’ll turn 10 deg, rolling and yawing, bringing my fingers from -12 to -11 deg below horizontal. My left hand will settle slightly before releasing its support. My left move is (2, 0, -3) mm with rotation (0, 1, 0) deg, then my left gripper opens. My right move is (6, -19, -24) mm with rotation (-7, 2, -7) deg, keeping my right gripper closed.
move {"left": {"delta_xyz": [2, 0, -3], "delta_rotation": [0, 1, 0], "gripper_closed": false}, "right": {"delta_xyz": [6, -19, -24], "delta_rotation": [-7, 2, -7], "gripper_closed": true}} - tool
{"state": {"terminated": false, "success": false, "arms": {"left": {"fingertip_pose": {"position_mm": [322.1603, -343.2213, 435.9098], "quaternion_wxyz": [0.8859, 0.0866, -0.1548, -0.4285]}, ...}, "right": {...}}}}
Across an episode
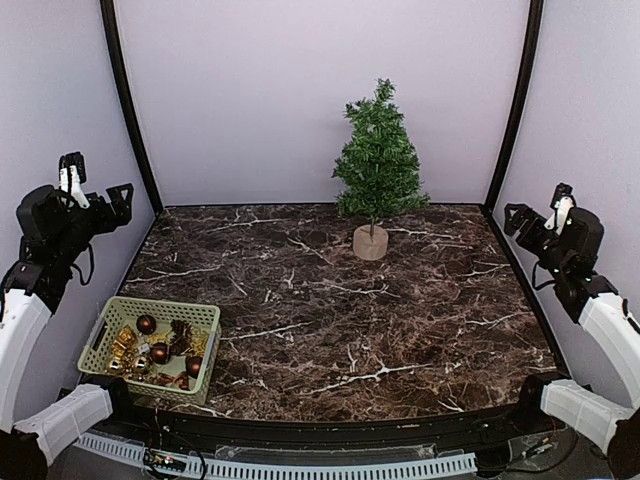
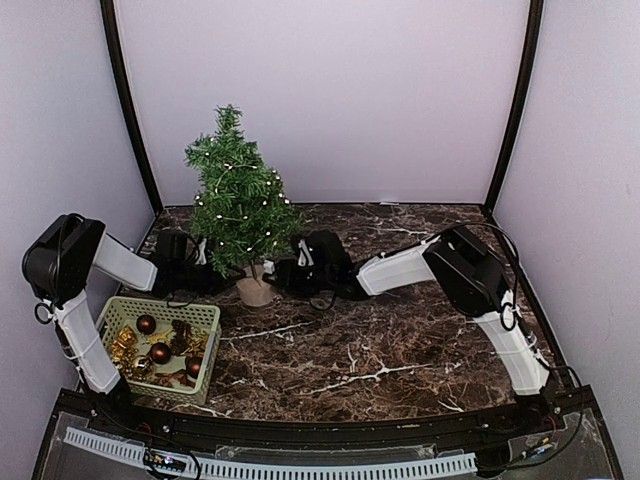
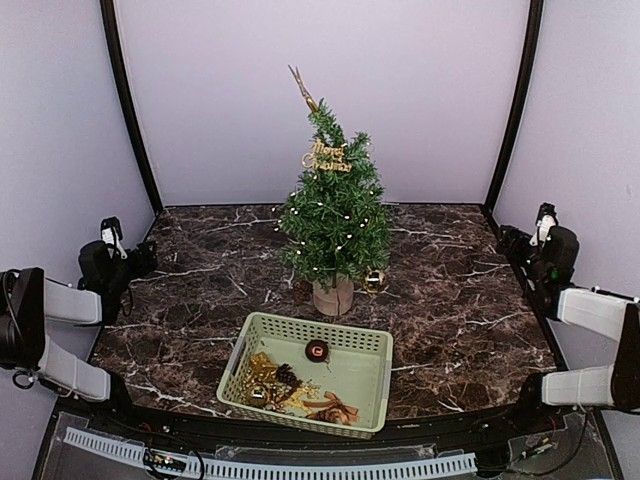
The head camera at three points in the same episode, which runs for 284 steps.
More tasks
Conversation
system: describes the robot, units, frames, and themovetool.user:Task: <instruction>.- Each step has three messages:
user: the state JSON (fingertip poses in mm, joint angles in degrees, gripper commands), then a label and image for each camera. The label gives the camera's horizontal and vertical field of view, which differ between episodes because the cameras do.assistant: the chain of thought and onemovecall, with arguments{"left": {"delta_xyz": [x, y, z], "delta_rotation": [rx, ry, rz], "gripper_closed": b}, "right": {...}}. Translations are in mm and rotations are rotation vectors in degrees, in the arm's current fingertip frame.tool:{"state": ...}, the measured state after the move.
user, thenassistant: the final state and views, then a completion reply with no tool call, which ends the episode.
Row schema
| Column | Type | Meaning |
|---|---|---|
episode | string | Episode ID, ep_<index> |
episode_index | int32 | 0 to 499, grouped by task |
task | string | Task key |
robot | string | Robot name |
instruction | string | Task instruction |
messages | list of messages | The conversation |
images | list of Image | Every image in the conversation, in order of appearance |
tools | string | The OpenAI tools list as JSON: the move function and its JSON schema |
num_steps, num_images | int32 | Steps (tool calls) and images in the row |
A message has role, content, tool_calls, and tool_call_id, with one Arrow schema for every message. Fields a message does not use are null. content is always a list of parts {type, text, image_url: {url}}, and the k-th image part is images[k].
Conventions
- The fingertip frame has its origin midway between the fingertips, +X toward the fingertips, +Y across the jaws, and +Z = X × Y.
- A move is applied once, as T_goal = T_tip · T_delta. The controller drives the arms until they arrive or stop moving, then sets the gripper.
- An idle arm holds: its move is zero.
- Moves carry no step count or duration. How long a move runs is up to the controller.